


Vaman V3 — 3D-Printed Quadruped Experiment (Paused Version)
After Vaman v2 successfully implemented AI-based movement (voice + gesture + object find/stop), the next challenge was to move beyond wheels. Vaman v3 explored legged locomotion — building a quadruped robot capable of walking and balancing.
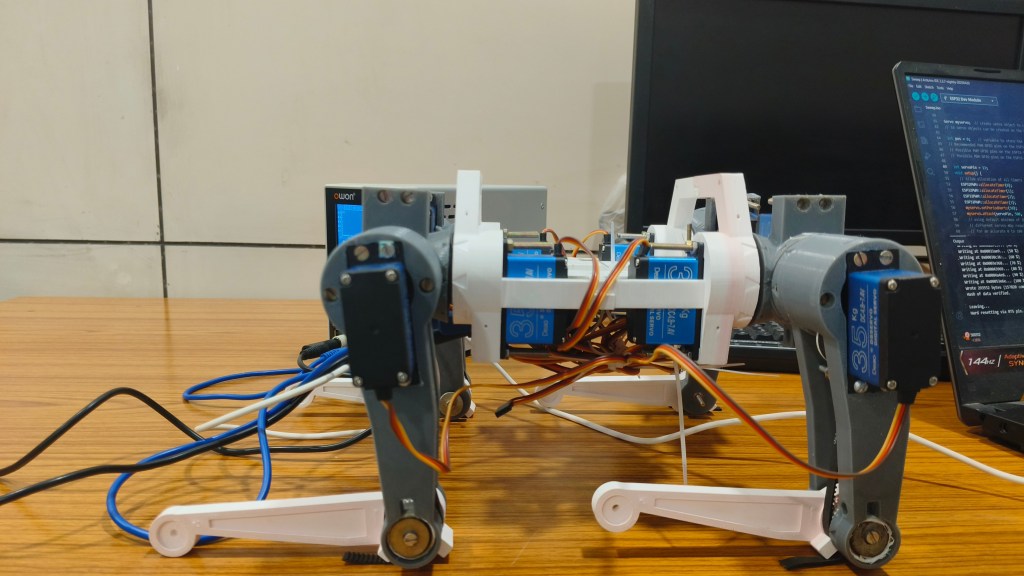
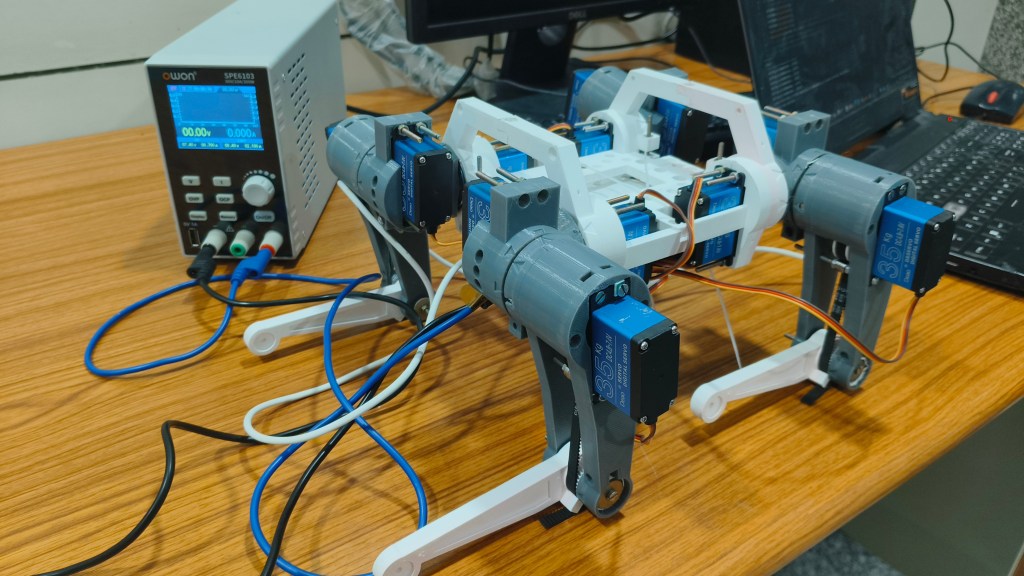
Important Note
The mechanical design (3D model) of the Vaman v3 quadruped was not created by us.
We used an existing open-source design and made some modifications to fit our servo motor, based on this reference video 🔗.

We did not copy code or electronics, only the mechanical STL body structure was taken from this model so we could focus on:
- Motor control algorithms
- ESP32 real-time control loop
- Voice + gesture interaction
- IMU balancing + gait logic
- LLM-based voice assistant integration
Features it Could Have Completed
| Sr. No. | Feature Category | Feature Name | Description / Outcome |
|---|---|---|---|
| 1 | Autonomous Navigation | SLAM-based Mapping & Navigation | Build live map using LiDAR + IMU fusion and walk autonomously in unknown indoor environments. |
| 2 | Computer Vision | Object Detection & Tracking | Detect object/person (YOLO) and walk toward it. |
| 3 | Multimodal Interaction | Voice + Gesture Combination Control | Robot moves only when both input modes match. |
| 4 | Security & HRI | Voice Authentication | Only authorized user can control robot. |
| 5 | Companion Mode | Human Follow Mode | Follows a human continuously using realtime pose tracking. |
| 6 | Surveillance Mode | Autonomous Patrol | Walks on predefined route and logs data. |
| 7 | Adaptive Gait Control | IMU-based Stabilization | Self-balances automatically when pushed or tilted. |
| 8 | Terrain Adaptation | Adaptive Stride Adjustment | Walks on uneven / rough terrain. |
| 9 | Firmware Management | OTA Updates | Firmware updates wirelessly without connecting cable. |
| 10 | Power Efficiency | Low Power Gait Mode | Automatically reduces torque & gait speed when battery is low. |
| 11 | Natural Language Interface | LLM Assistant | Commands like “Vaman walk 2 meters” → robot moves intelligently. |
| 12 | Future Expandability | Object Fetching | Finds object using vision and brings it back (future capability). |
Version History
| Version / Prototype | Platform | Brief Description | Status / Why It Stopped |
|---|---|---|---|
| VAMAN V1 | Jetson Nano (Wheeled) | Camera + voice + gesture testing (proof of concept). | Stalled due to PWM control issue & USB serial detection problems. |
| VAMAN V2 – P1 | Cardboard Chassis (Wheeled) | ESP32 + Gesture + IMU tests, basic locomotion verified. | Chassis bent because cardboard couldn’t carry battery + electronics weight. |
| VAMAN V2 -P2 | Metal Chassis (Wheeled) | Johnson motors + BTS7960 + ESP32 + voice & gesture fully functional. | No failure — successfully working. Stopped because we realized wheeled robots cannot handle uneven terrain → decision to upgrade to quadruped (VAMAN V3). |
| VAMAN V3 (Current) | Quadruped (3D printed — mechanical) | 35kg·cm servos + IMU balance + walking gait. | Paused due to servo brownouts + mechanical tuning + parallel national rocket competition workload. |
Why the project was paused
- High-current servo power issues
- Battery + load → brownouts when walking
- Mechanical structure from downloaded STL wasn’t strong enough for long tests
- At the same time, team was selected for National/ International Rocket/Cansat Competitions, time shifted to that
What happened in the background (parallel development)
| Area / Module Worked On | Status | Responsibility |
|---|---|---|
| LLM-based Robot Assistant | ✅ Completed | Gaurav + Anshuman |
| Voice Assistant (Offline VOSK) | ✅ Completed | Deepanshu |
| Voice Authentication (Resemblyzer) | ✅ Completed | Deepanshu |
| Face Authentication (Face Recognition ) | ✅ Completed | Gaurav |
| Multi-modal Input Pipeline (Gesture + Voice → command) | ✅ Completed | Team |
Some Snaps and Clips
Walking
Torque Test
Finetuned LLM (Eleven Labs API Used for TTS)
Finetuned LLM ( Full Integrated Model )

Zero PCB Testing Phase
Circuit

Vaman Schematic
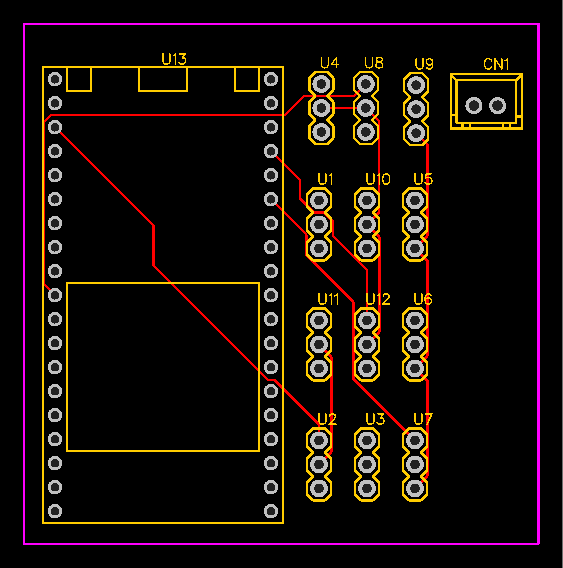
Vaman PCB Layout
My Learnings
- Even if the idea and skills are strong, lack of dedicated time kills execution.