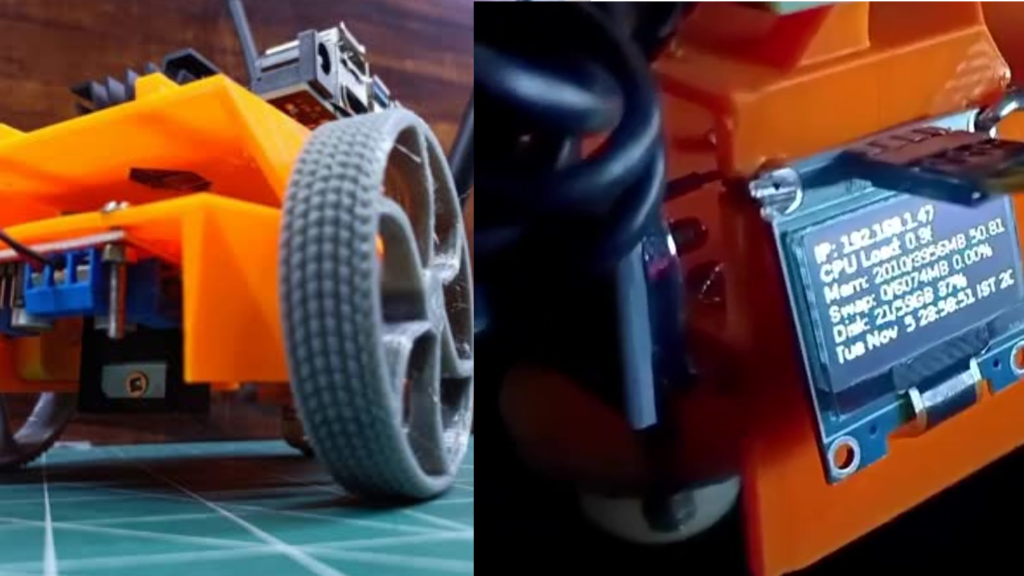
Features
- Wireless robotic control over 5G Wi-Fi
- Real-time camera feed through Jetson Nano
- Basic movement control (forward / reverse / turn)
- Vision + motion handled on-board by Jetson Nano, no microcontroller
Components Used
- Hardware
- Jetson Nano (main controller + processing)
- Motor Driver L298N (controls motors from Jetson GPIO)
- Logitech C270 Camera (vision feed)
- Intel 5G Wi-Fi Module (high-speed wireless control)
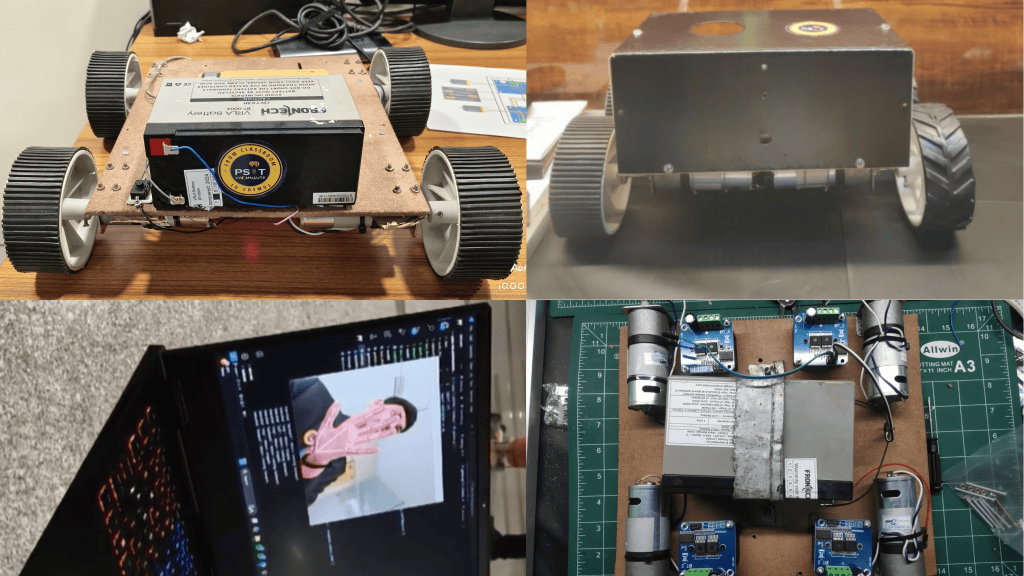
- JetBot Chassis (compact robot platform)
- Software
- Python motor control scripts (GPIO based)
- Wi-Fi command interface
- Camera streaming script using Jetson Nano
How it Works
- Robot receives control commands wirelessly over 5G Wi-Fi
- Jetson Nano drives the motors via L298N motor driver
- Live camera feed is streamed from the Logitech C270
- Jetson Nano handled both processing and motor control without any microcontroller.
Performance
- Instant movement response, no input lag
- Smooth live video feed from the camera
Media Availability (Important Note)
⚠️ Since Vaman v1 was an early prototype, only one working video is available
(limited documentation because the chassis was temporary and used only for testing).
Limitations Identified
- PWM control limitation
- Jetson Nano’s PWM pins could not reliably control the motor driver due to outdated PWM/GPIO library support.
- USB serial issue
- When attempting to offload motor control to a microcontroller, the Jetson Nano failed to detect the microcontroller over USB serial.
- Space constraints
- The JetBot chassis didn’t have enough space to mount all components (Jetson + motor driver + microcontroller).
Conclusion
- Vaman v1 successfully proved:
- Jetson Nano can independently handle motion + camera over Wi-Fi
- But the limitations led to the next stage:
- Vaman v2, bigger chassis + dedicated motor controller
My Learnings
- Running vision + motion together on the Jetson Nano, wireless control over 5G Wi-Fi with a live camera feed and no external microcontroller
- Driving motors from Jetson GPIO through an L298N motor driver using Python scripts
- Streaming a Logitech C270 camera feed with instant, lag-free movement response
- Jetson Nano PWM/GPIO library limits make reliable motor control hard, a dedicated motor controller is the better design
- Debugging USB serial detection issues when offloading motor control to a microcontroller
- Chassis size matters: plan space for compute + motor driver + microcontroller before building, which led to Vaman v2