


Inspace ISRO Rocket Avionics PCB
The InSpace ISRO Rocket Avionics PCB is a compact and reliable avionics system designed for our rocket Trishul, responsible for telemetry, navigation, data logging, and event control during flight.
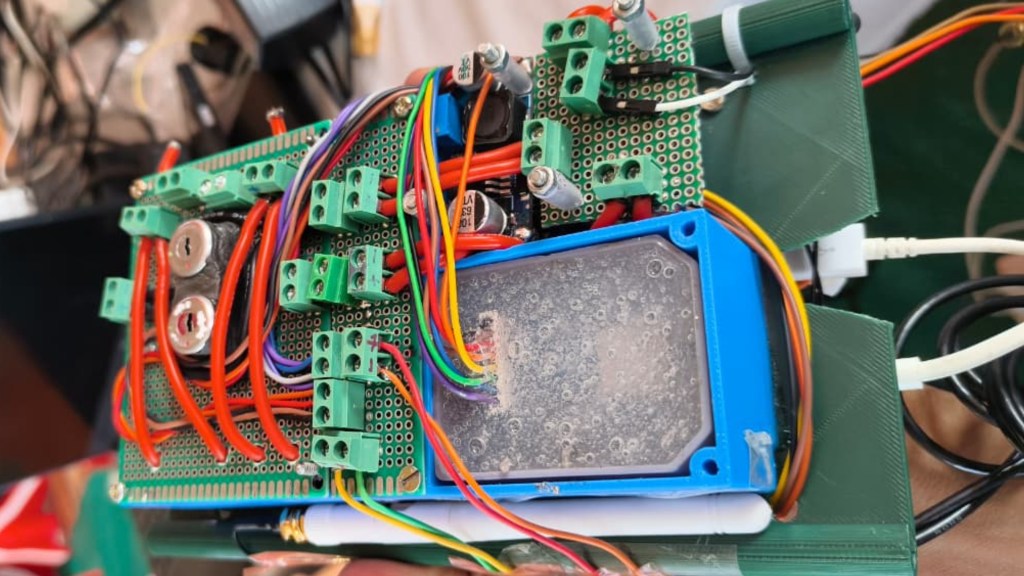

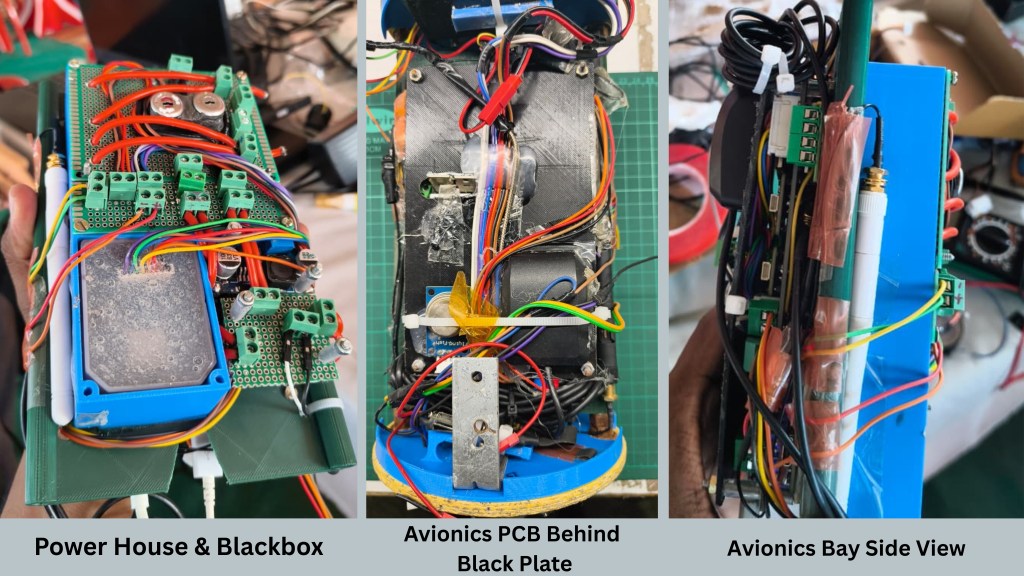
Team Role
| Riya, Shikha, Rahul & me | PCB design, component selection, sensor + communication integration |
| Dev, Anmol, Ritish & Sparsh | Parachute, Separation Technique Mechanical integration, rocket airframe compatibility |
| Priyanshu, Gaurav & Anshuman | Ground Control Station (GCS) — telemetry dashboard, live data visualization |
Features
- Dual-Controller Architecture
- Raspberry Pi Pico 2 (primary flight computer) + Arduino Nano 33 BLE Rev Sense 2 (secondary controller)
- Dual Telemetry Links
- XBee S3B Pro (RF telemetry)
- Quectel EC200U CN (4G communication for backup location)
- Multi-Sensor Suite
- BNO085 (IMU), BMP390 (barometer), INA219 (power monitoring), MAX31856 (thermocouple), DS3231 (RTC)
- NavIC GPS Integration
- Uses India’s satellite positioning system for accurate rocket tracking
- Data Logging
- SD card module for black-box recording
- Event / Pyro Control
- MOSFET-based firing circuits for separation & parachute deployment
How it Works
| Raspberry Pi Pico 2 | Primary flight computer |
| Arduino Nano 33 BLE Rev Sense 2 | Secondary controller / backup |
| XBee S3B Pro | RF telemetry link |
| Quectel EC200U CN | 4G-based backup telemetry / location |
| NavIC GPS Module | Accurate real-time tracking |
| BNO085 | Orientation IMU |
| BMP390 | Altitude / pressure |
| INA219 | Power monitoring |
| MAX31856 | Temperature sensing |
| DS3231 | RTC — timestamping |
| SD Card Module | Black-box mission data logging |
| MOSFET Event/Pyro Board | Separation, pyros, parachute deployment |
Circuit
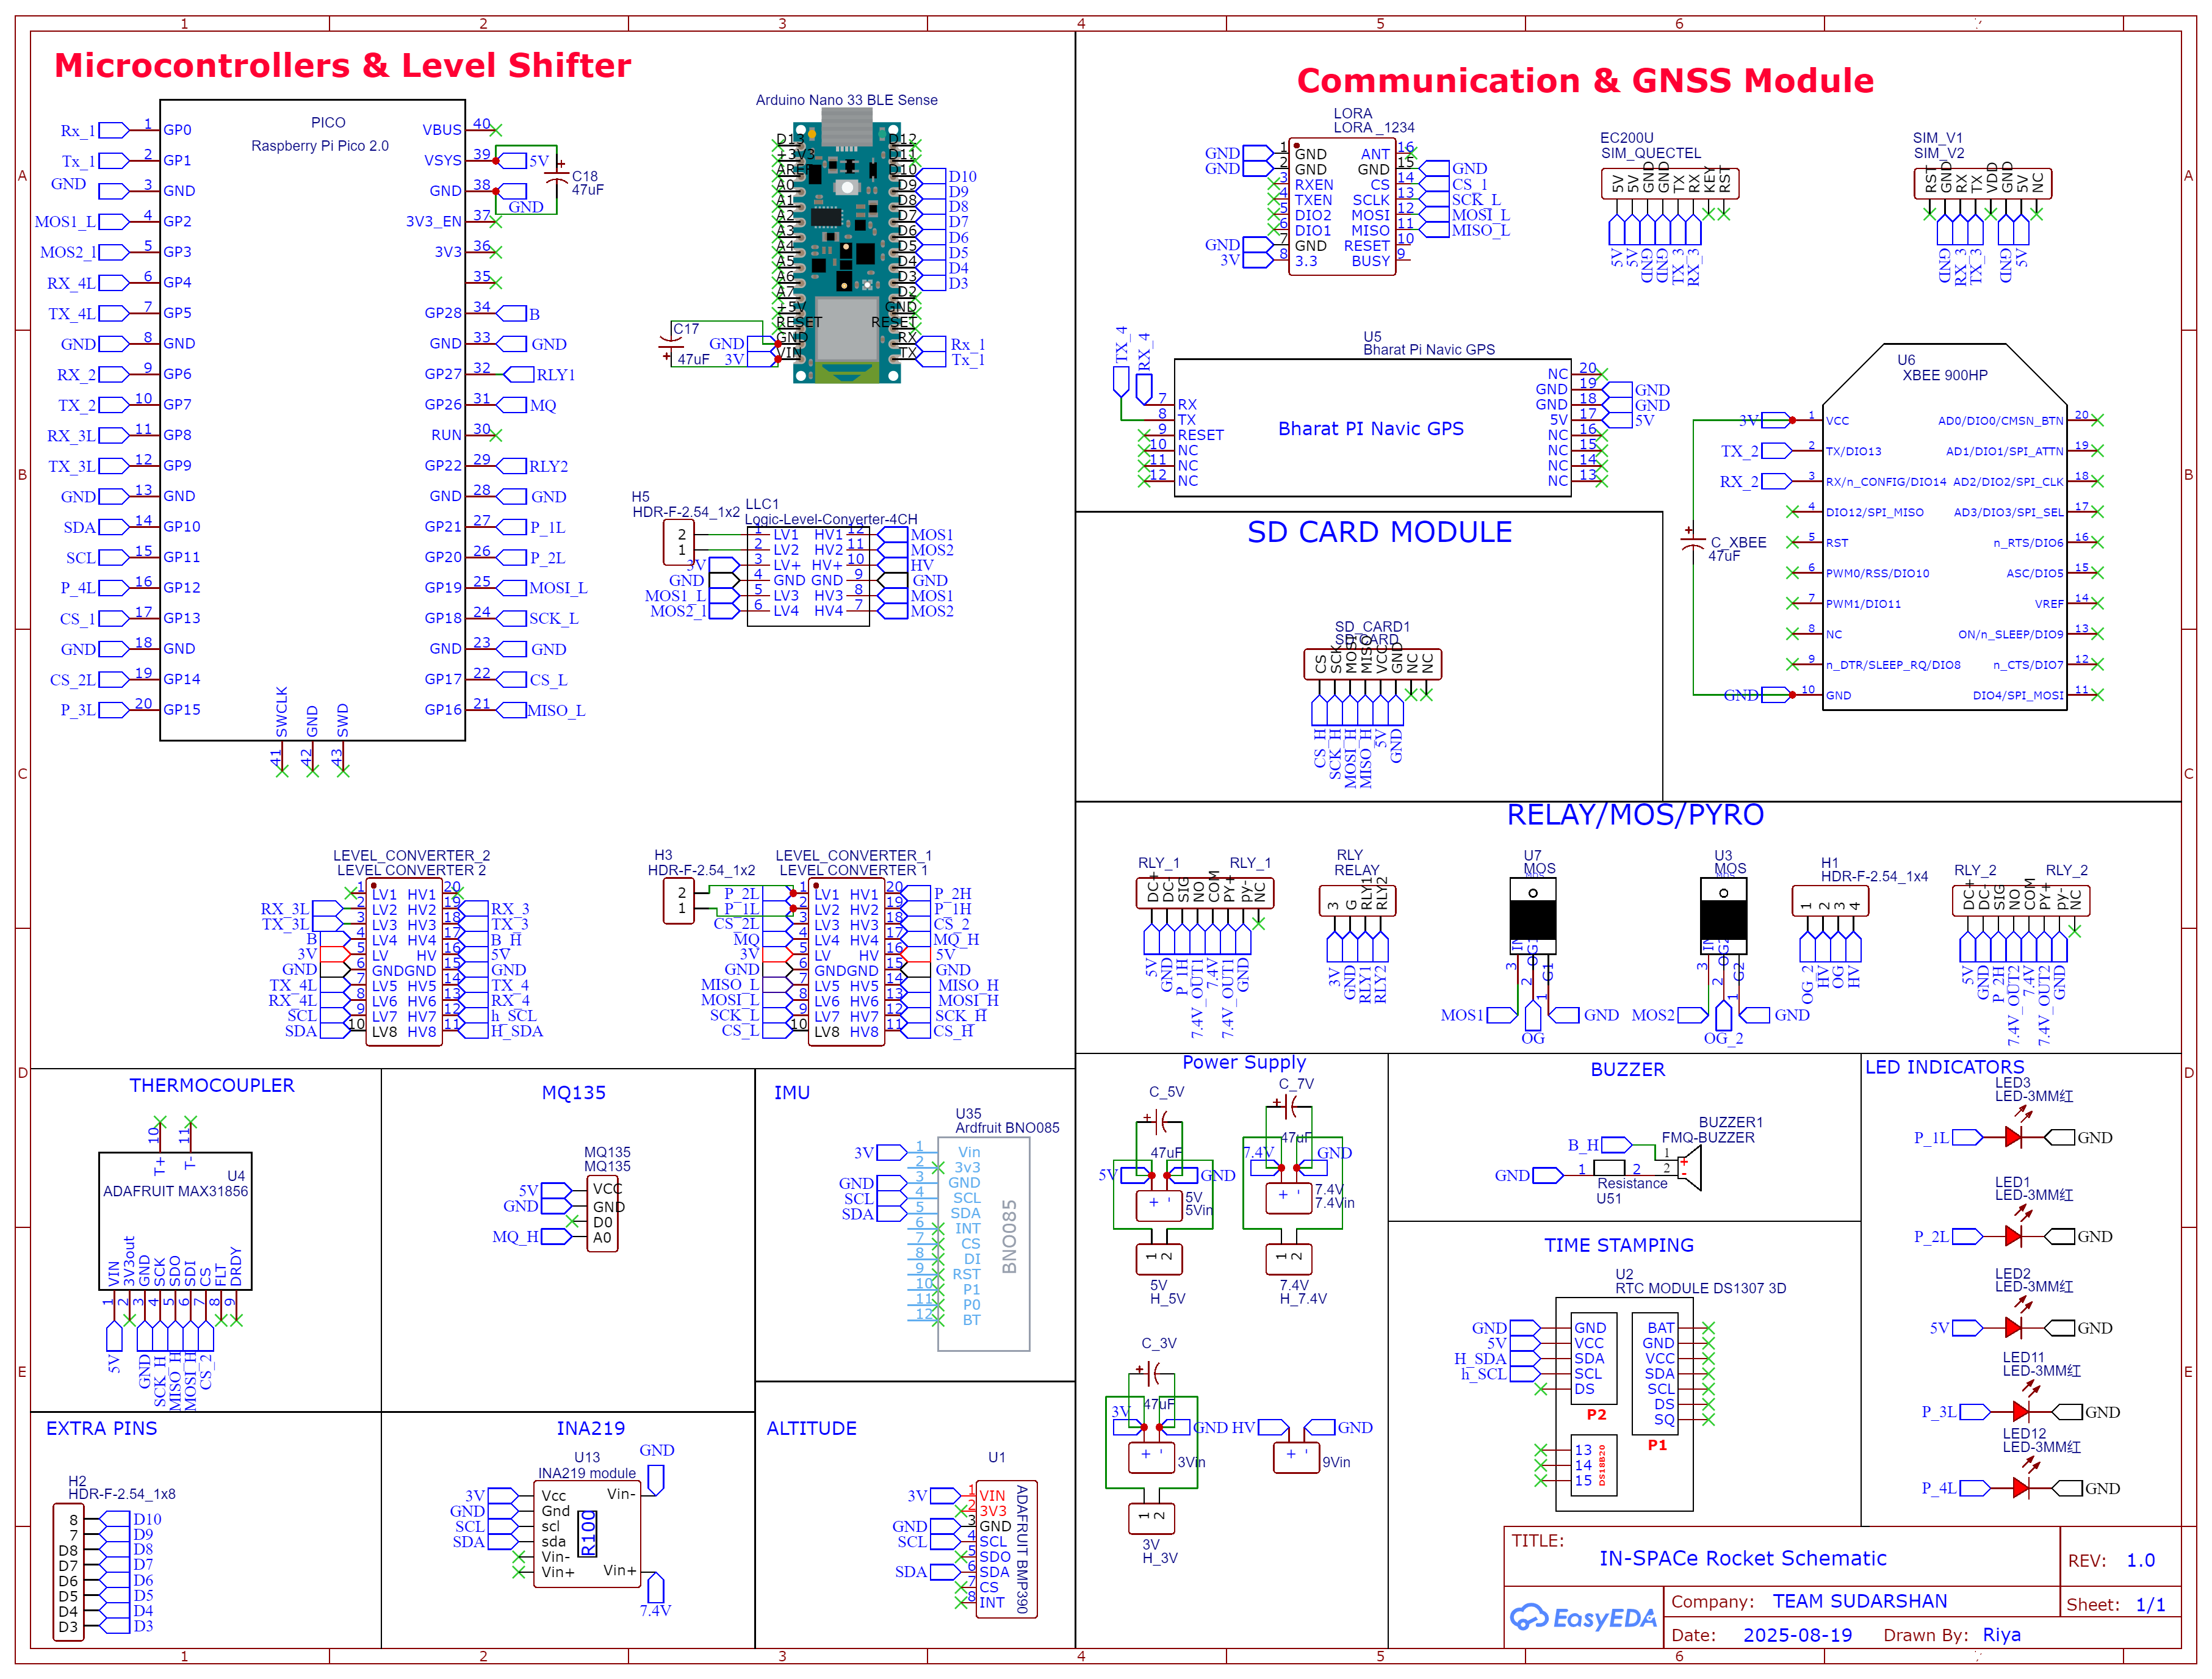
Schematic Layout
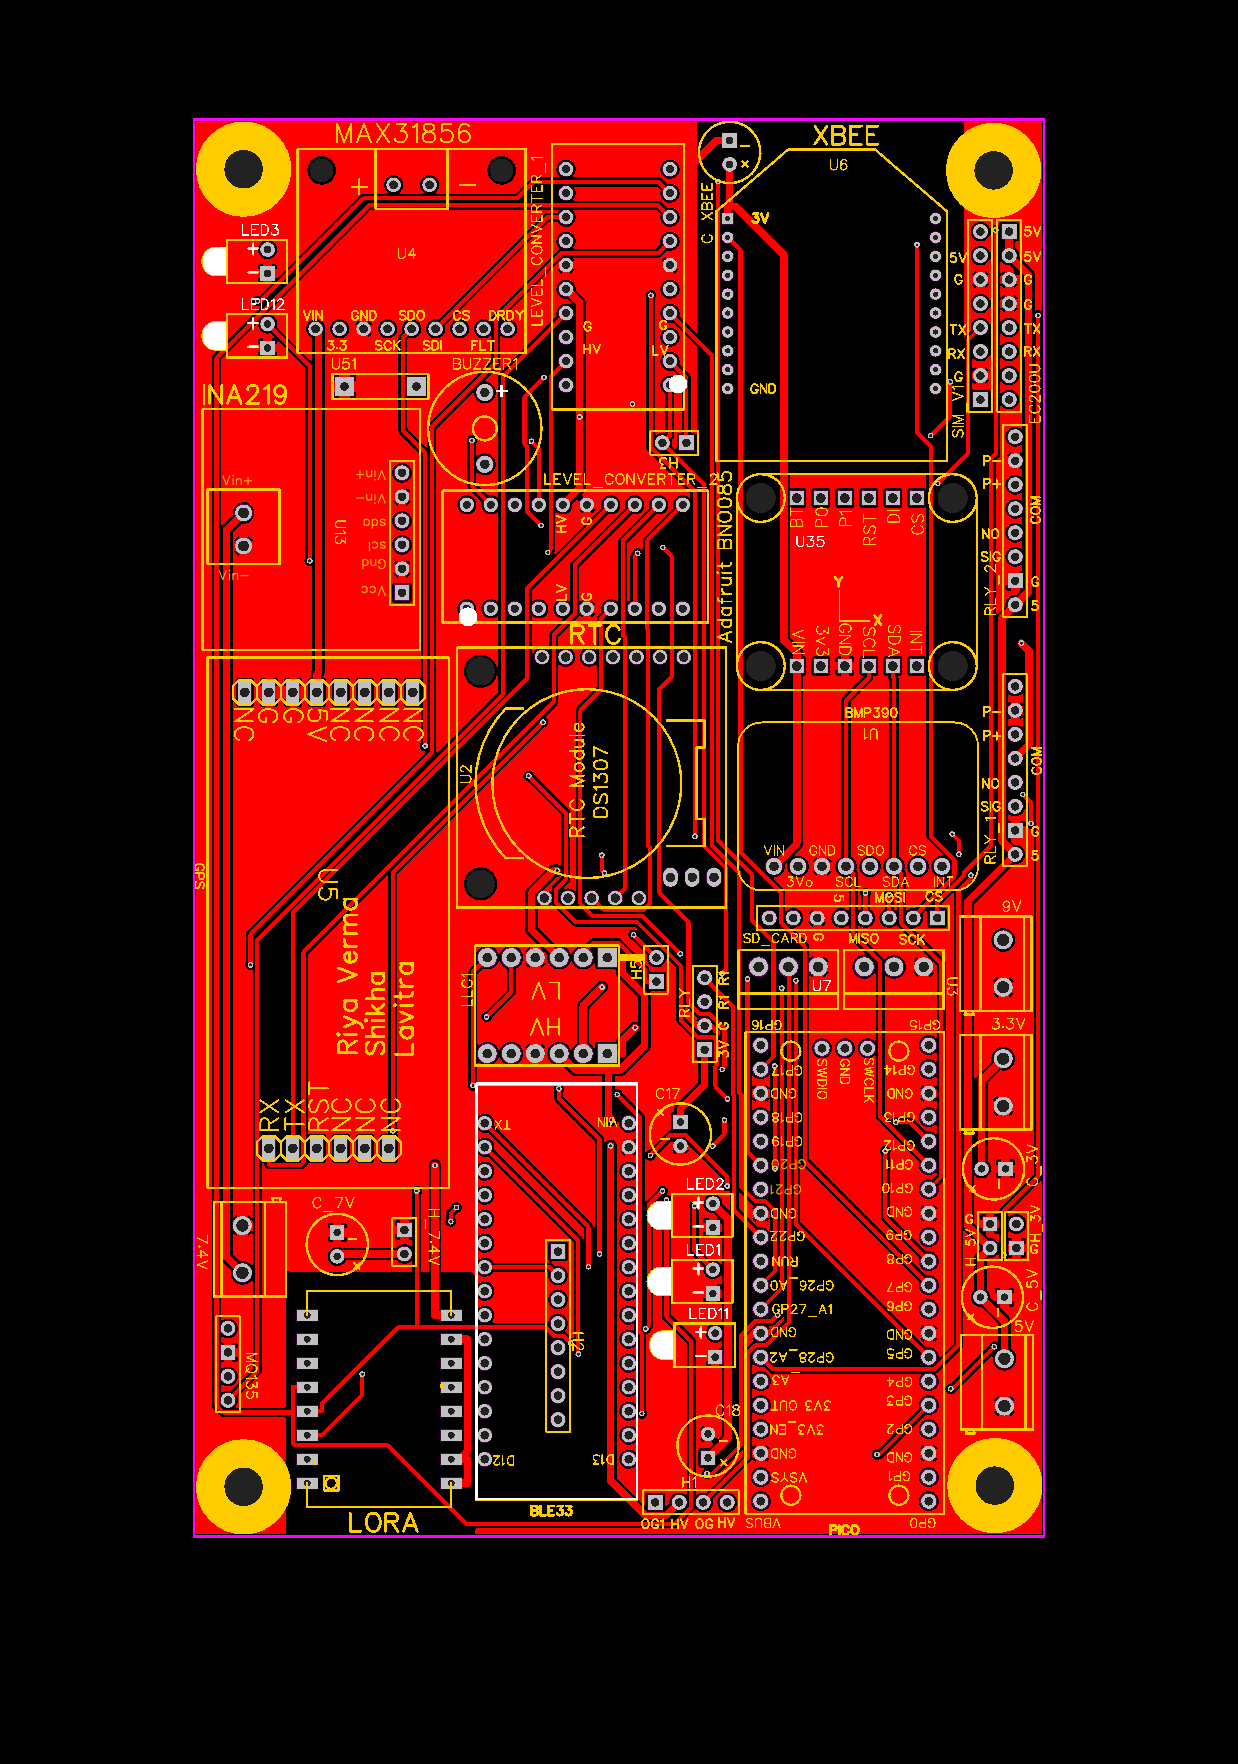
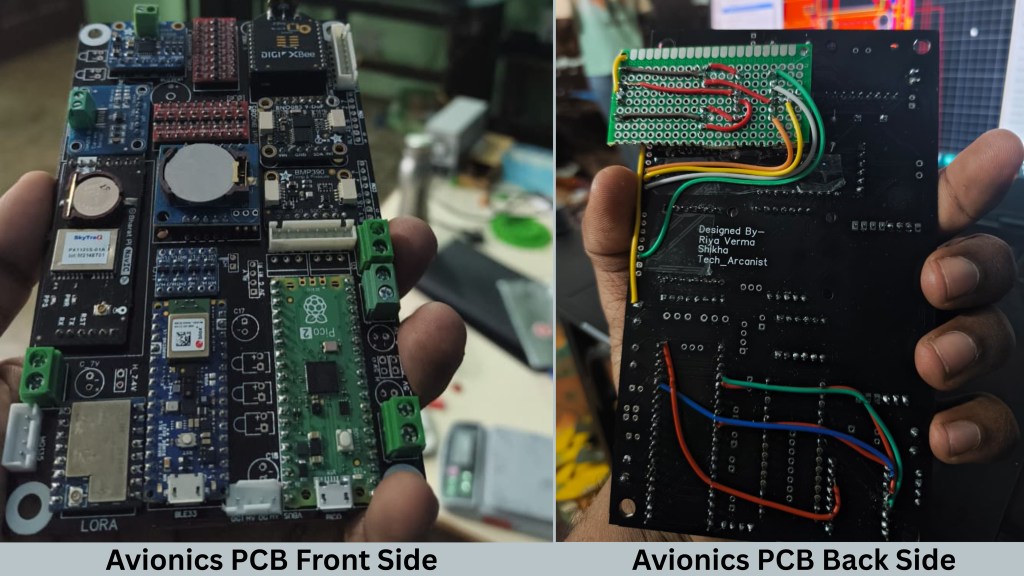
PCB Layout Front Side
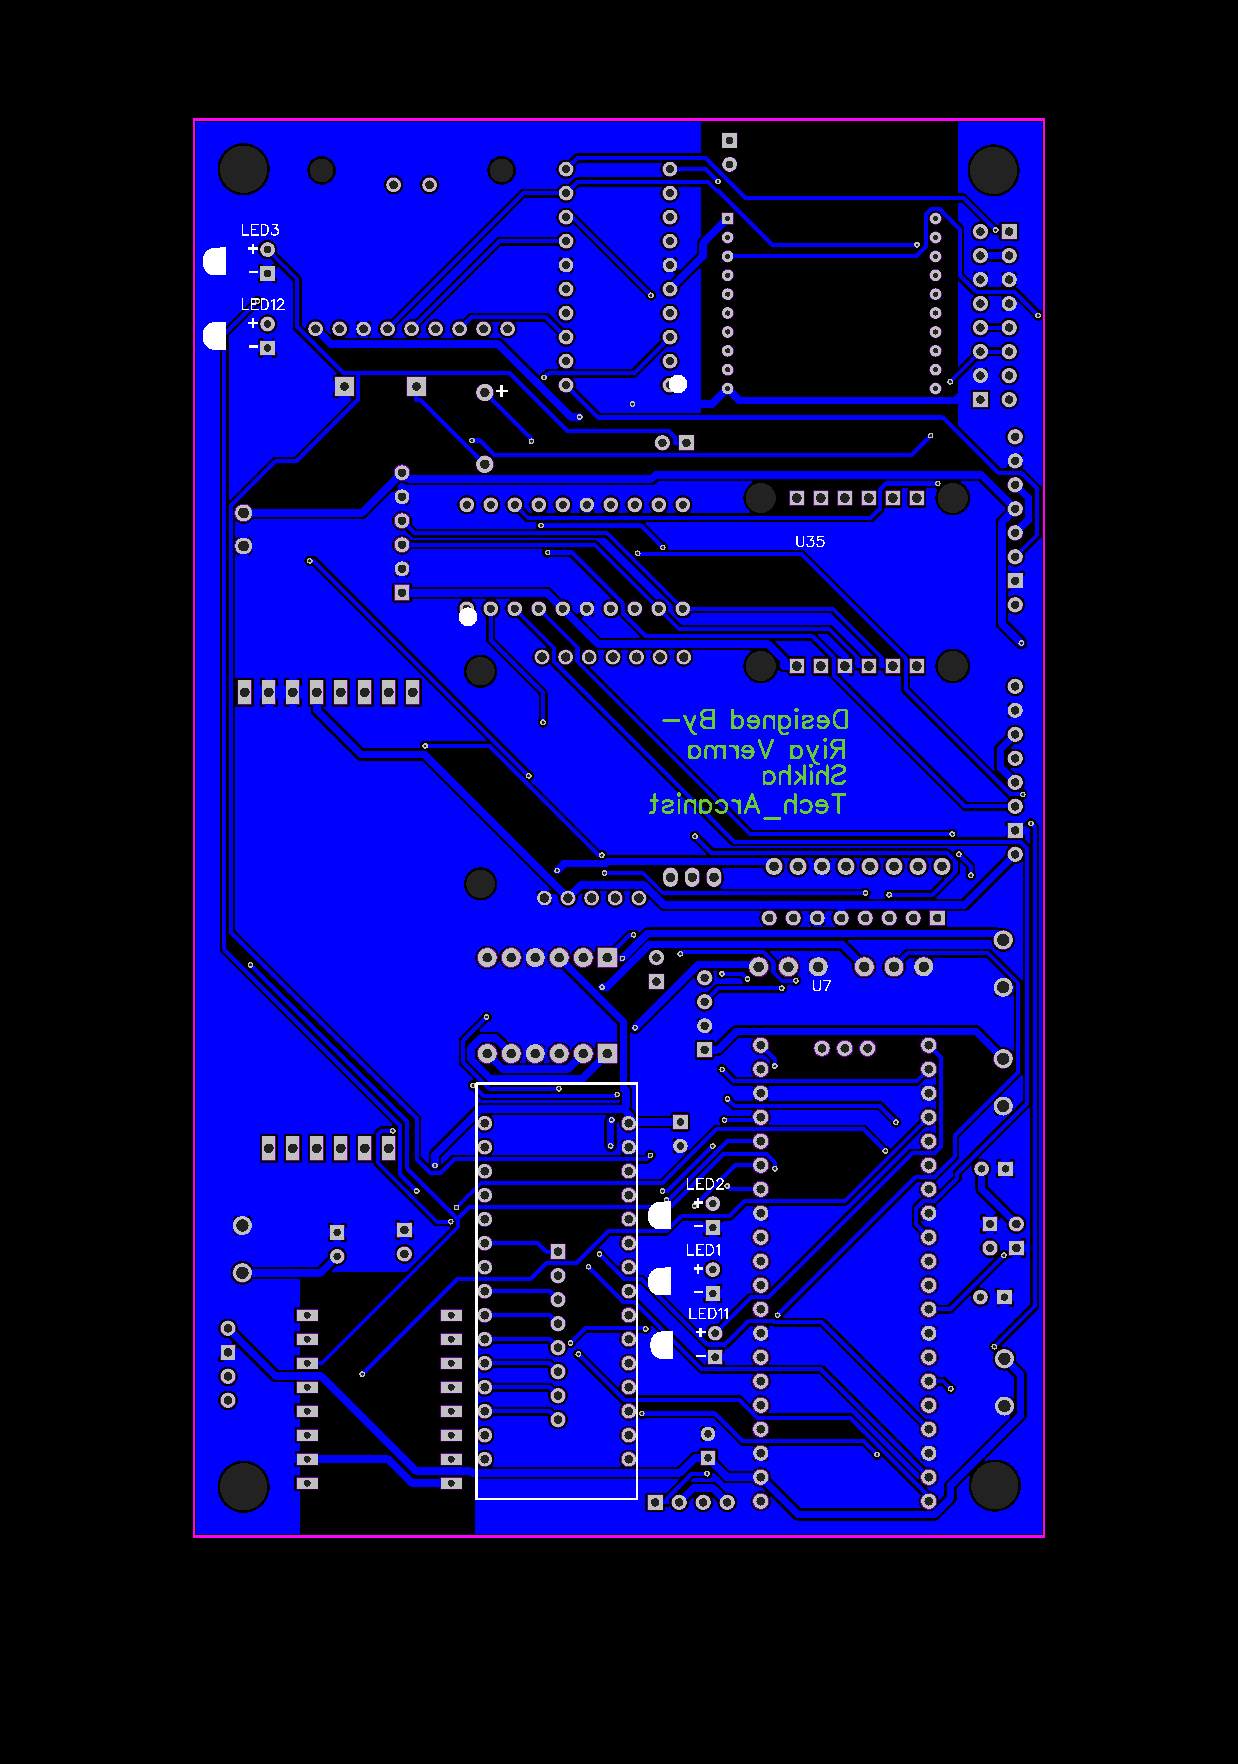
PCB Layout Back Side
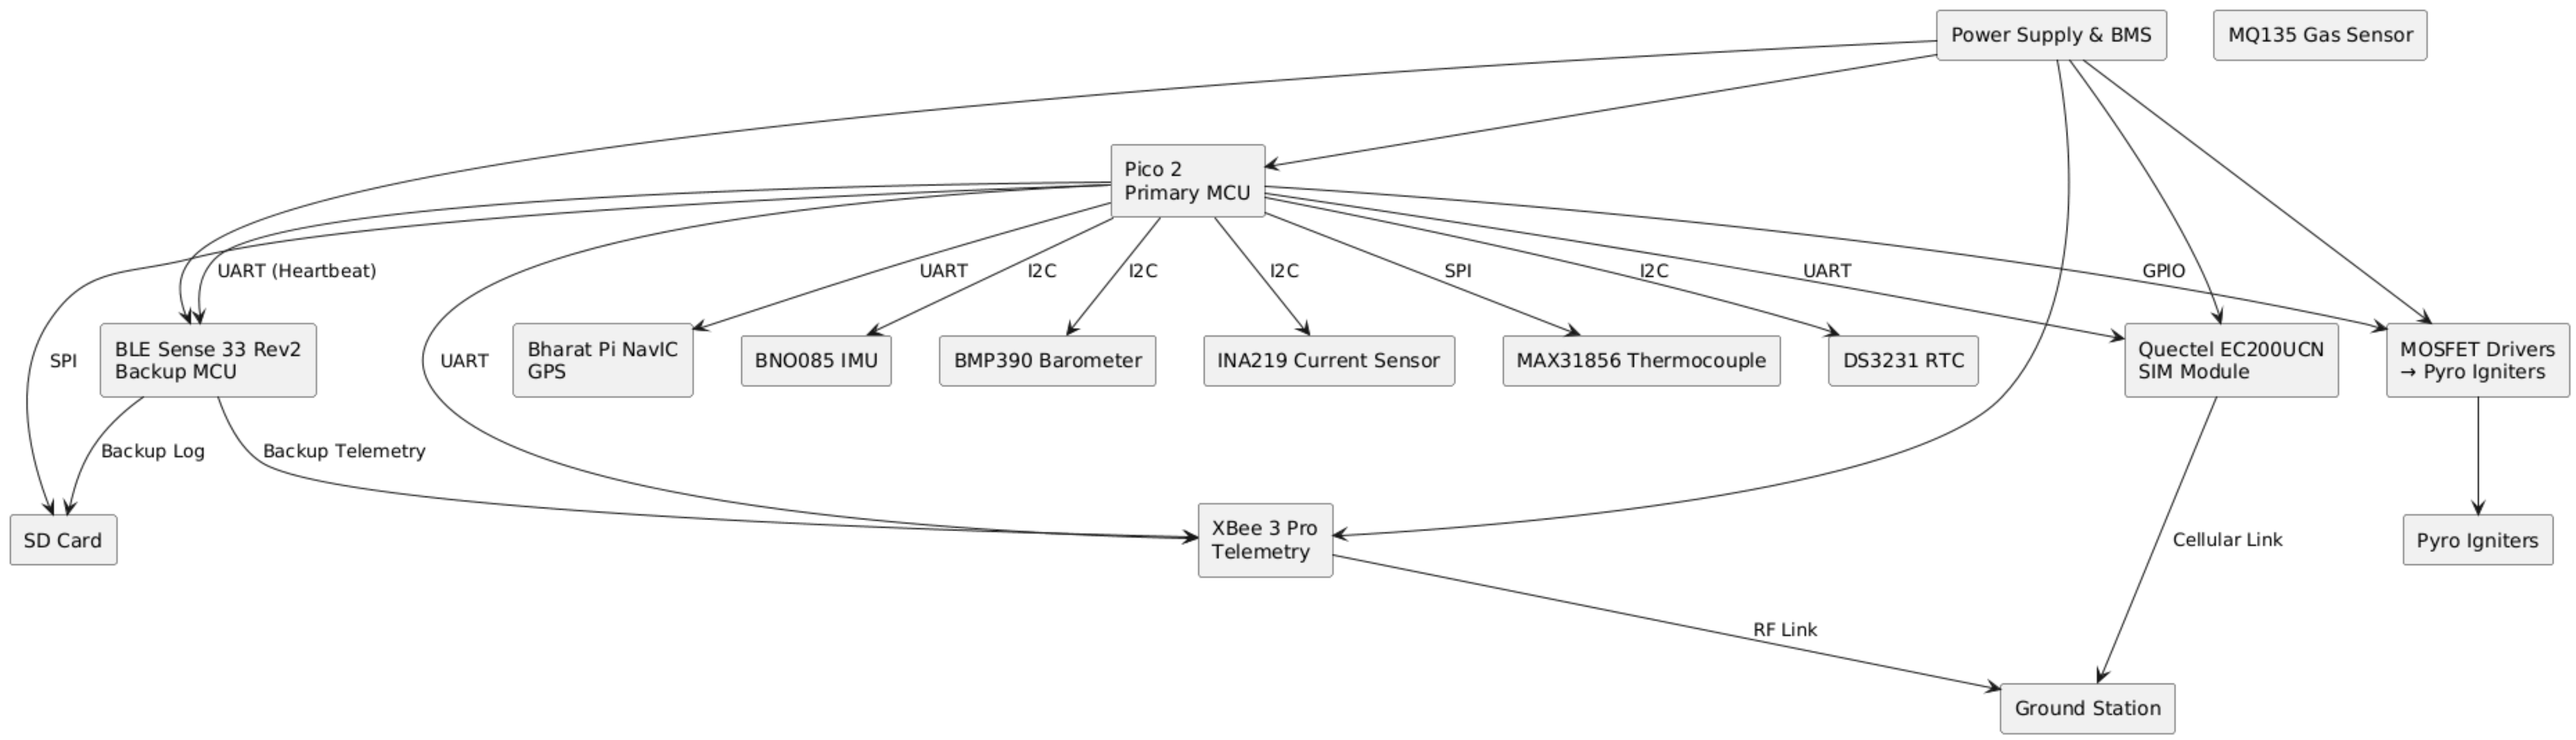
System Overview
- Collects sensor data during flight
- Transmits telemetry in real-time
- Logs mission data to SD card
- Controls events (separation / parachute deployment)
Working Demo
Serial Monitor Demo
GCS Demo
Competition Journey & Achievement
Our avionics PCB worked reliably during the launch — stable telemetry, successful event triggering, and accurate NavIC GPS tracking.
The performance and robustness of the avionics system helped us secure:
        🥈 2nd Prize — IN-SPACe Rocket Competition 🏆
My Learnings
- Learned how to design a flight-ready avionics system with a dual-MCU architecture.
- Understood critical event control (pyro channels, MOSFET drivers, safety isolation).
- Improved telemetry reliability with XBEE.
- Gained hands-on experience in rocket avionics integration with mechanical and launch workflow.