Team Role
| Riya, Rahul, Shikha, Arya & me | PCB design, component selection, sensor, communication integration, schematic review, routing, footprint creation |
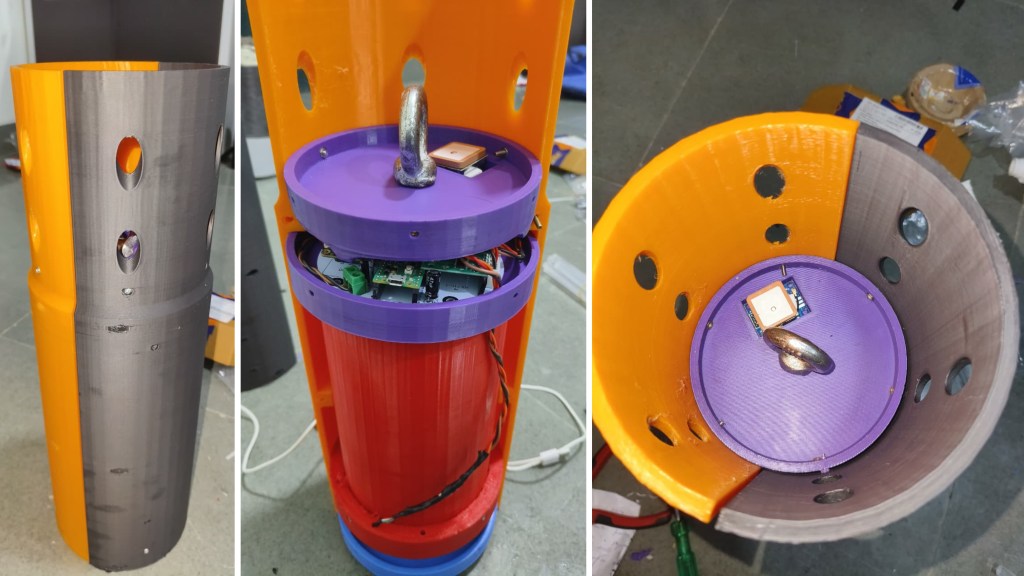
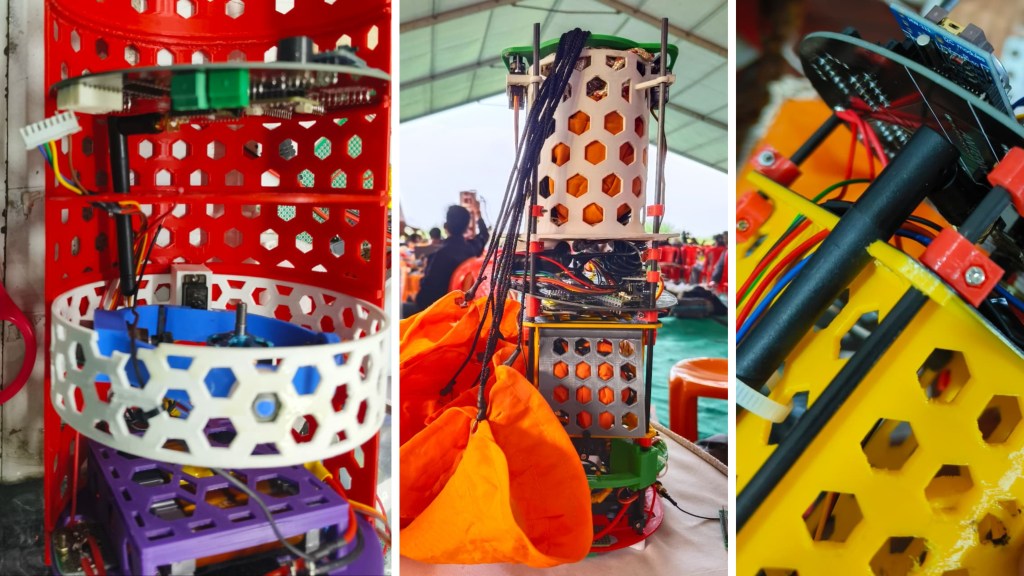
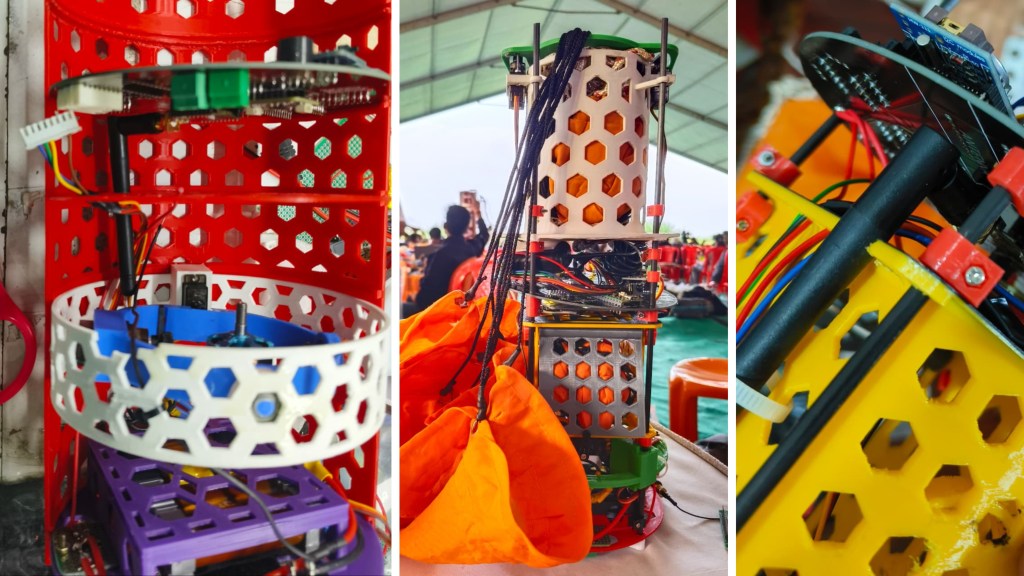
| Faiz, Rahul & Ritish | Mechanical design, CanSat structure, CAD, enclosure design |
| Priyanshu, Gaurav & Anshuman | Ground Control Station (GCS), live telemetry dashboard & data visualization |
Features
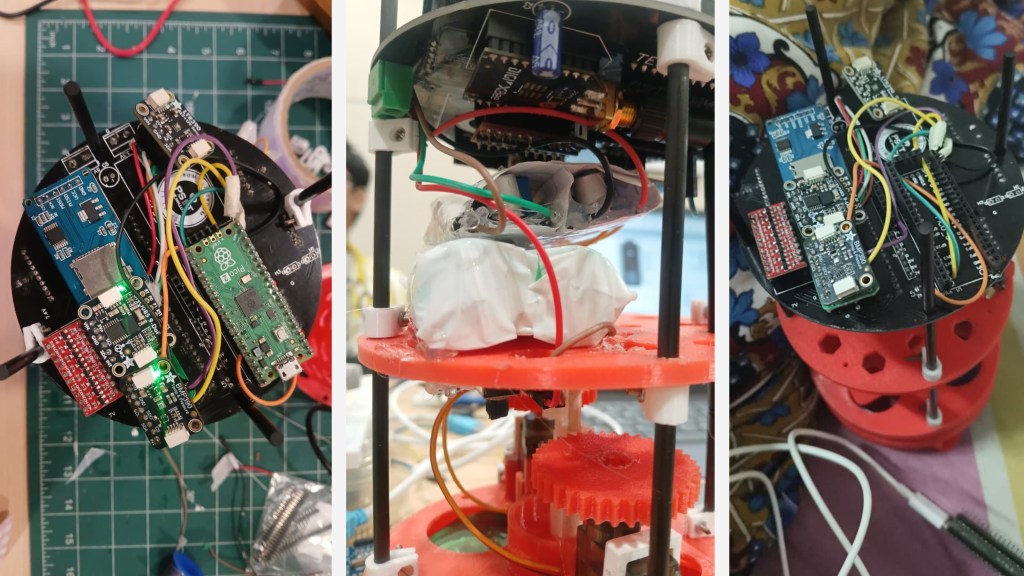
- Raspberry Pi Pico 2 + Arduino Nano BLE 33 Rev2 on the same PCB (BLE33 used for backup sensor data)
- LoRa + XBee + SIM module (multiple telemetry channels)
- SIM module used to send location via SMS
- Barometer-based altitude logging (BMP390)
- IMU-based orientation & stabilization (BNO085)
- Gas sensing (MQ4 and MQ135)
- GPS module (NavIC Bharat chipset) for accurate positioning
- SD card module for black box logging (keeps data safe even if telemetry is lost)
- Servo + BLDC motor connectors (used for gyro-based actuation)
- INA219 for power monitoring
- RTC (DS3231) for timestamping flight logs
Components Used
| Dual MCU Architecture | Raspberry Pi Pico 2 + Arduino Nano BLE 33 Rev2 (BLE used as backup for sensor data) |
| Multi-channel Telemetry | LoRa SX1262, XBee 3 Pro, SIM EX200U CN (SIM used to send GPS location via SMS) |
| Altitude Logging | BMP390 (barometer-based altitude measurement) |
| Orientation & Stabilization | BNO085 (IMU for attitude/orientation) |
| Gas Sensing | MQ4 (Methane) + MQ135 (Air quality / pollution) |
| Position Tracking | NavIC Bharat chipset GPS module |
| Black-box Logging | Micro SD card module (keeps flight data safe even if telemetry is lost) |
| Actuation Support | Servo headers × 3 + BLDC gyro interface (used for gyro mechanism) |
| Power Monitoring | INA219 |
| Time Stamping | DS3231 RTC |
PCB Layout / Hardware Design
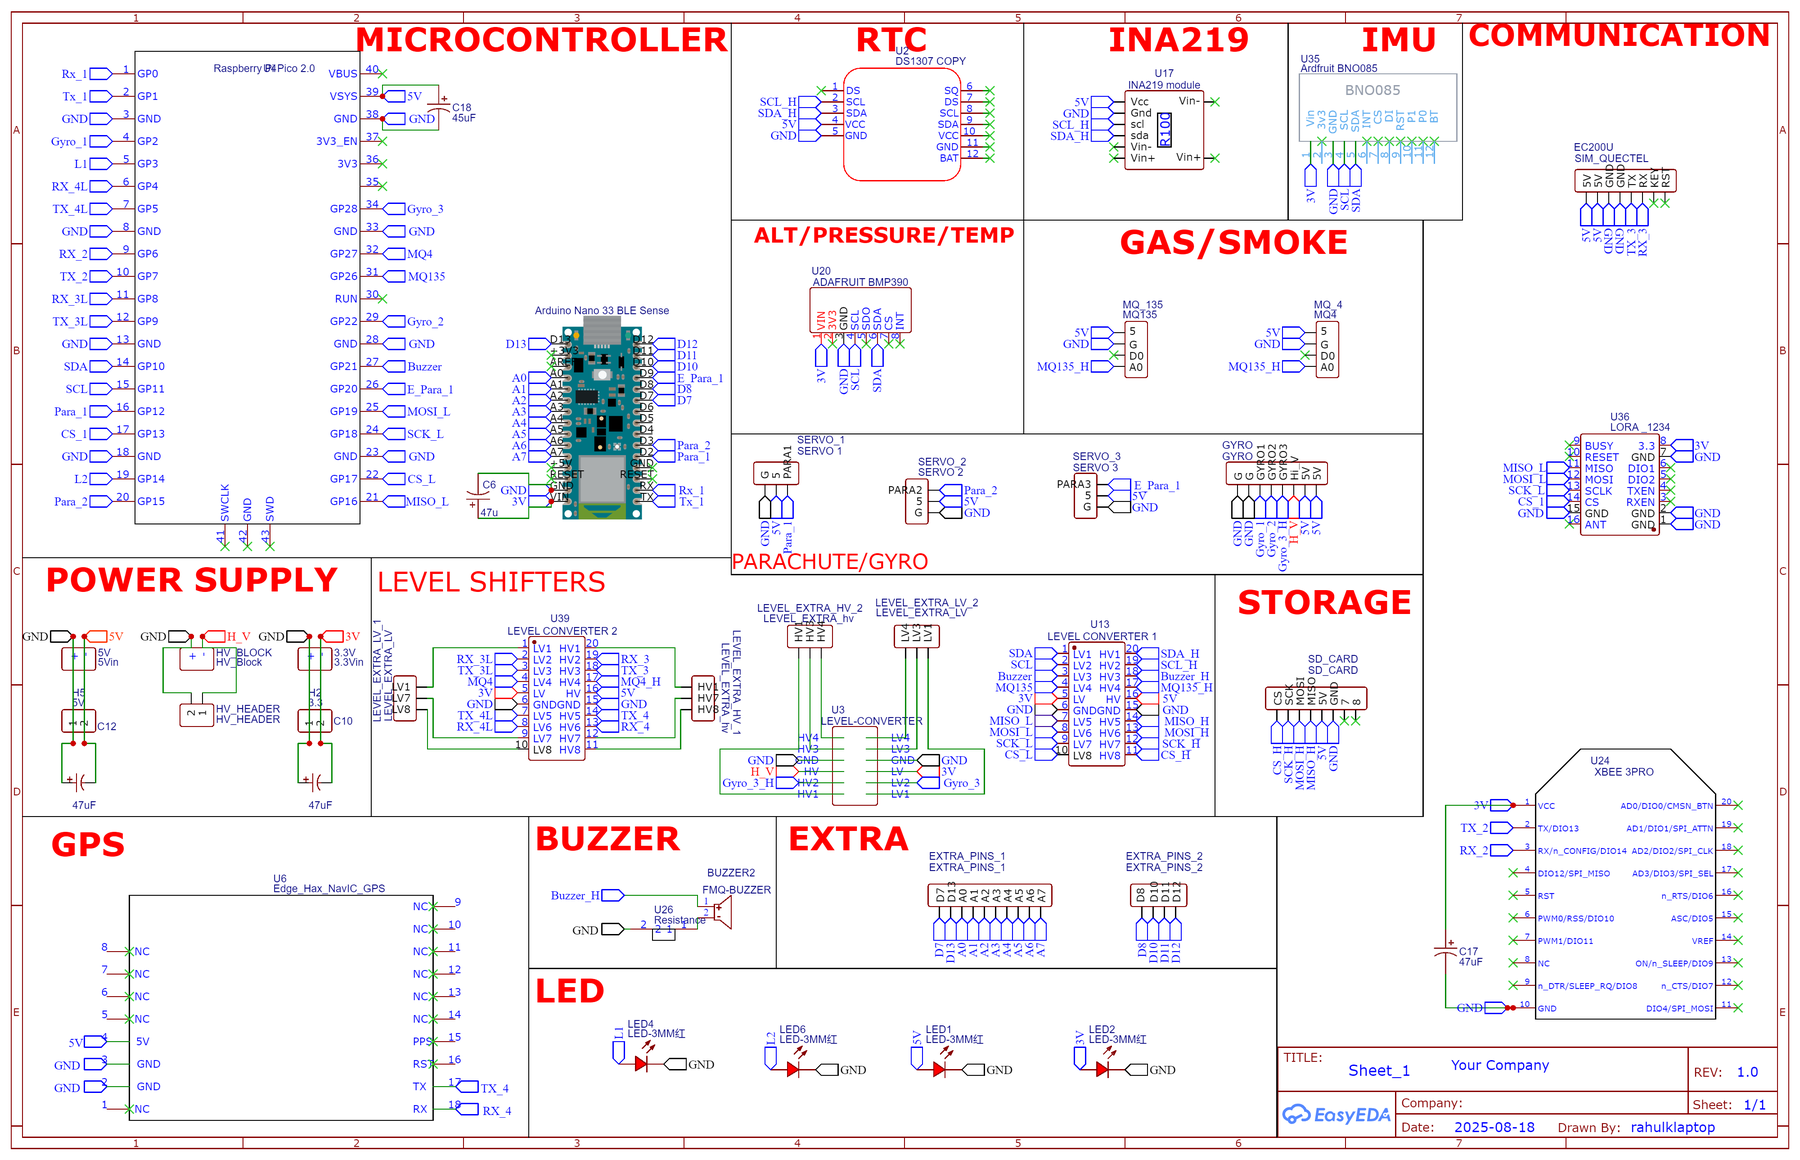
Schematic Layout
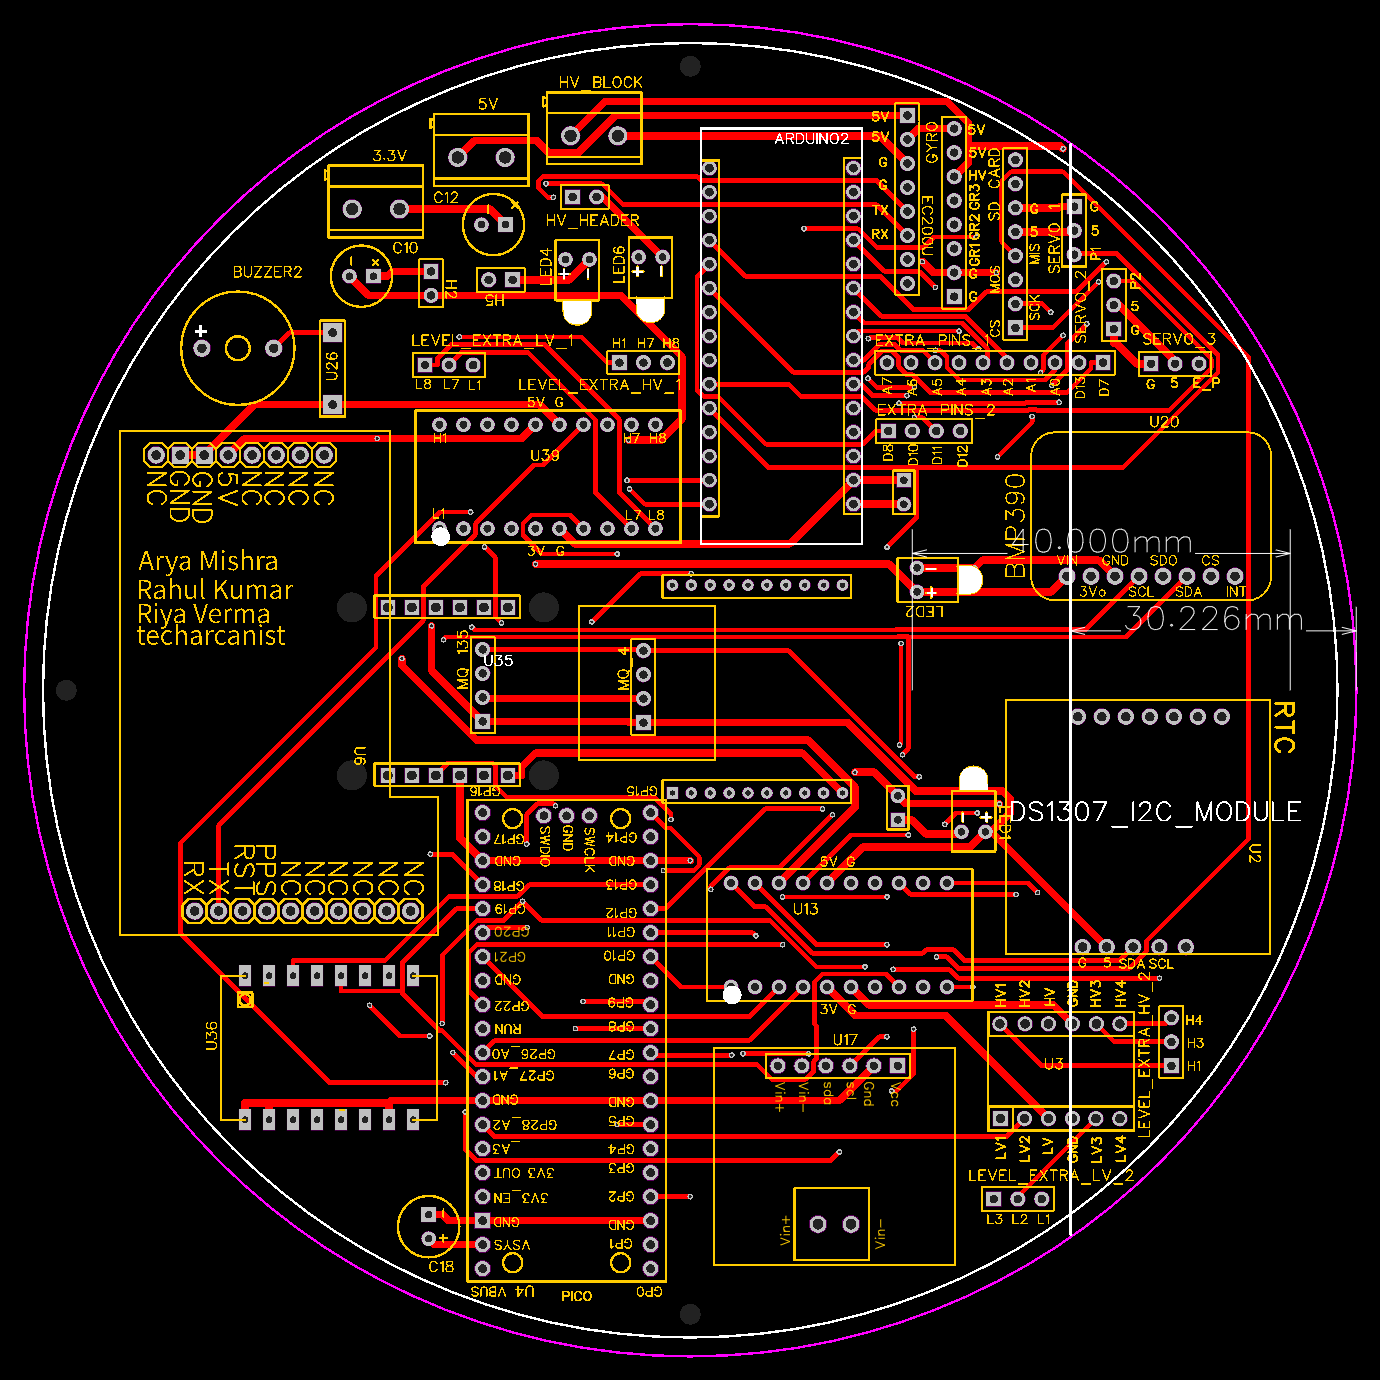
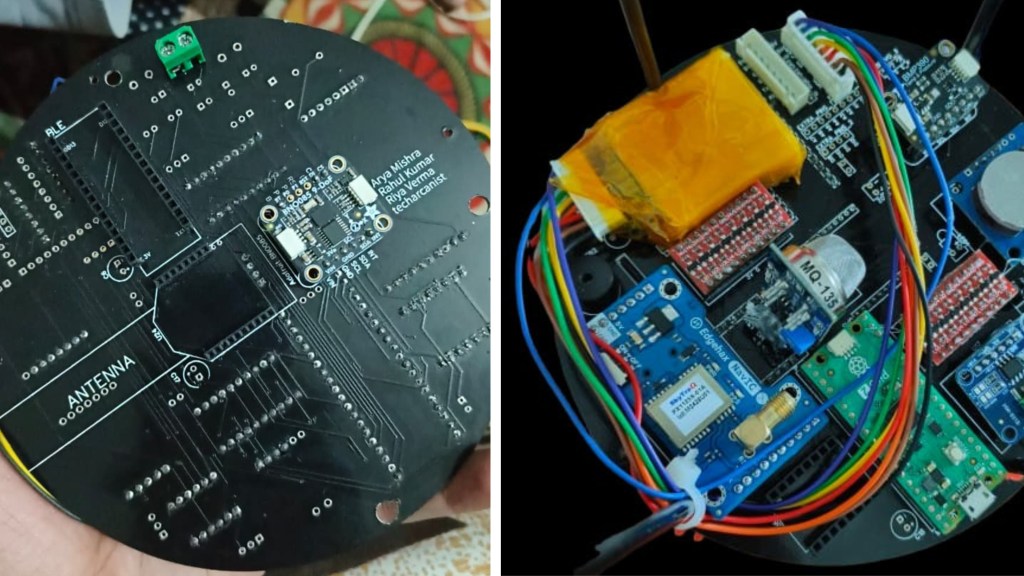
PCB Layout Front Side
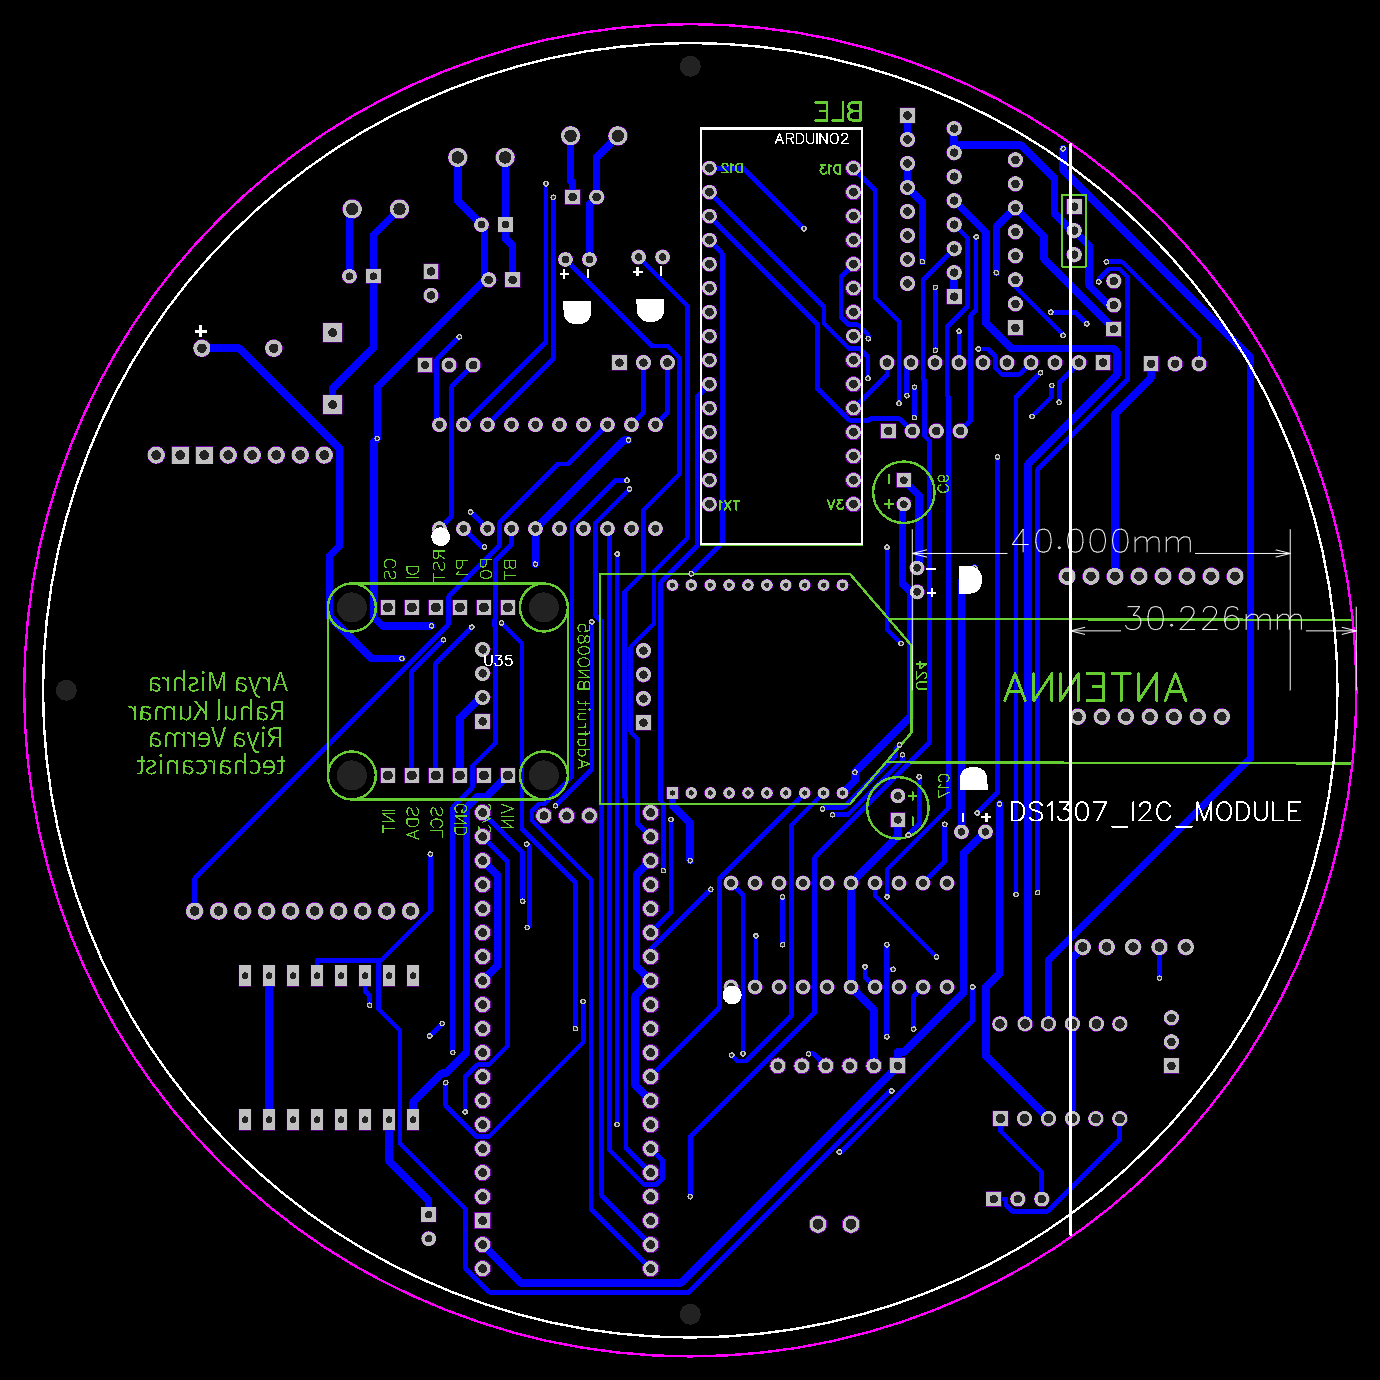
PCB Layout Back Side
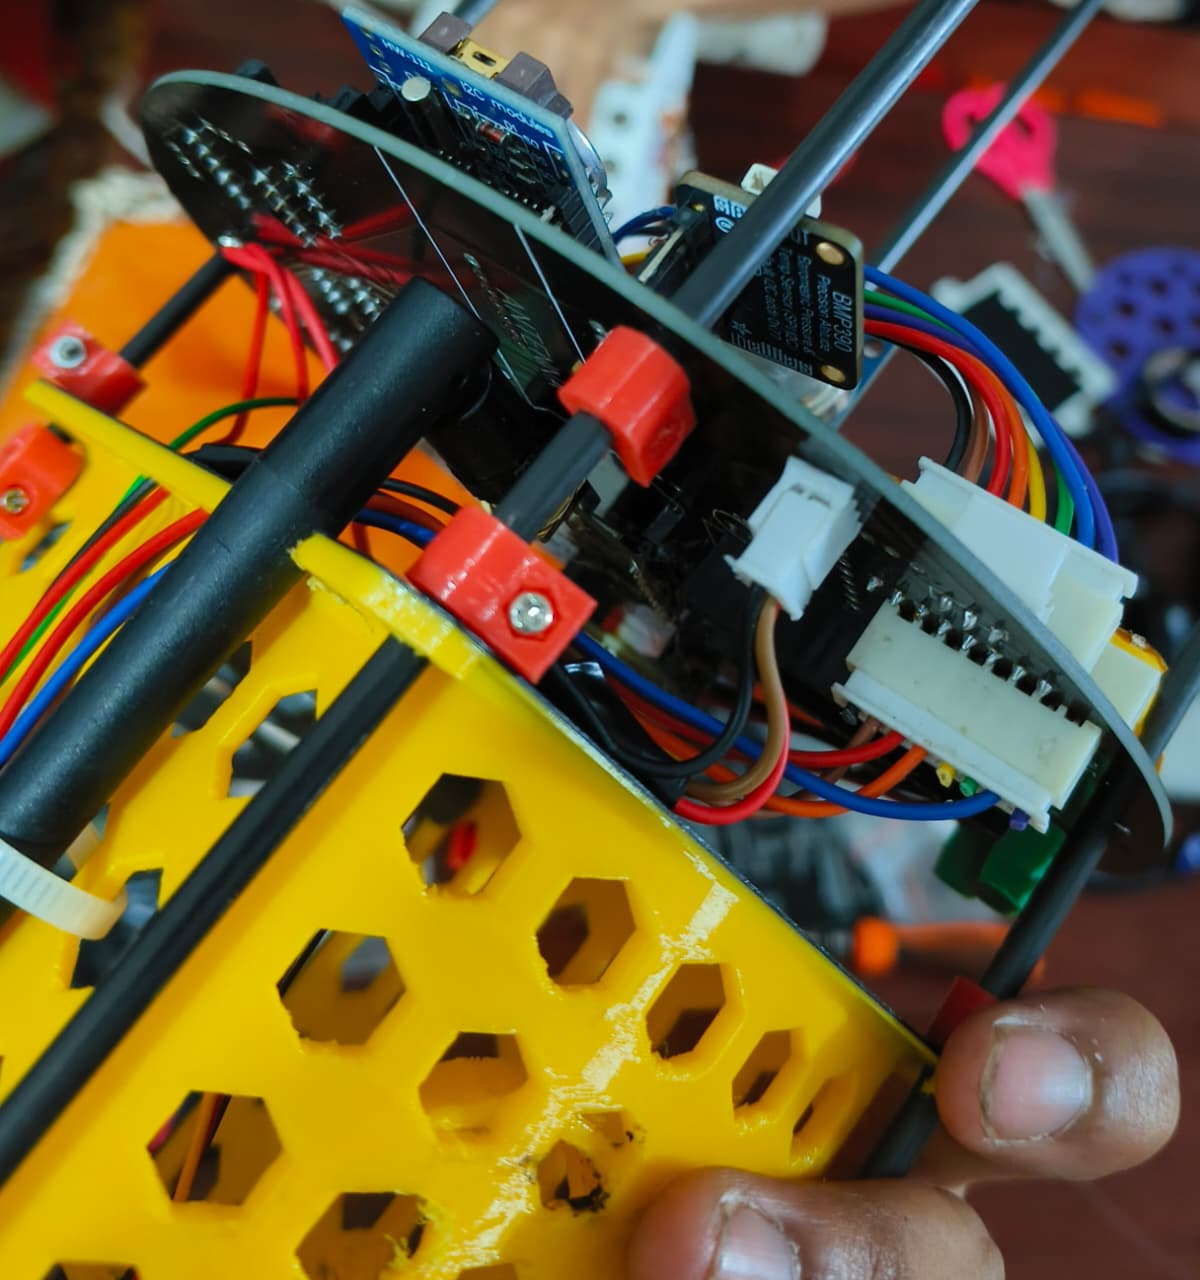
PCB Assembled Front Side
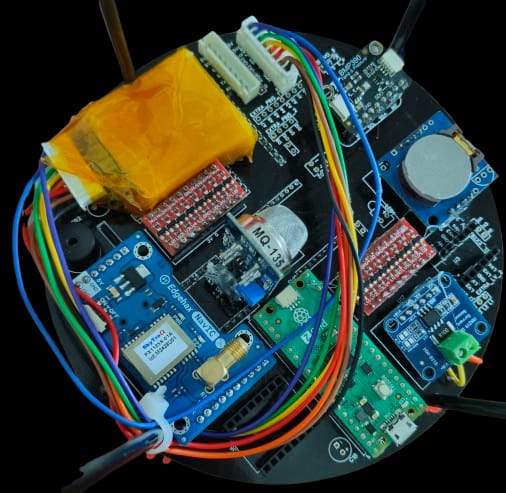
PCB Assembled Back Side
Competition Journey & Achievements
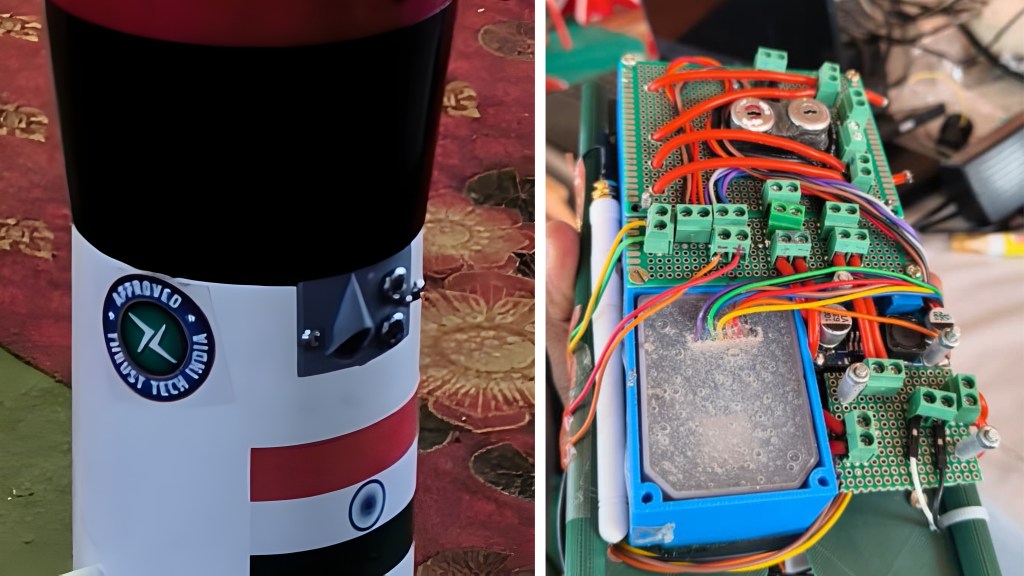
Our CanSat avionics PCB worked reliably during the competition, with stable telemetry, accurate GPS tracking, and secure black-box data logging. Its performance and design integration helped us win the 4th Position, Best CanSat Design Award🏆.
Github
My Learnings
- PCB design is not just routing, every component’s placement requires planning and logic (signal flow, trace length, noise isolation, accessibility).
- Improved my team coordination skills by efficiently dividing responsibilities between the avionics, mechanical, and GCS teams to ensure smooth workflow and integration.